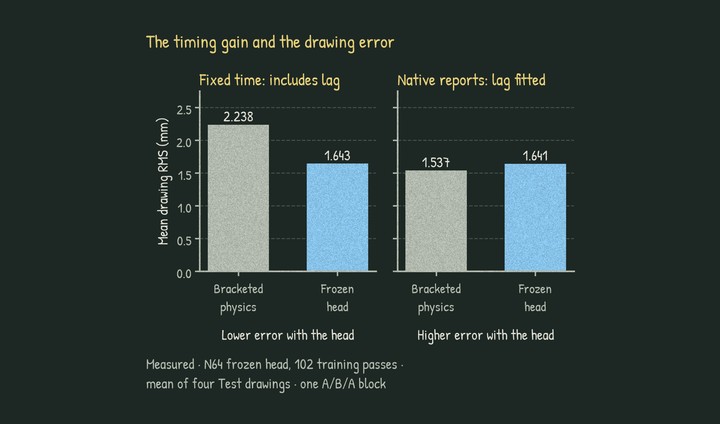
Teaching my drawing arm to keep learning
After part 6: direct motor drive, learning between drawings, feedback during a stroke, and a twin tested across days. The repeat floor is not a claim of one-millimeter control.
so-101machine-learningcontrolTags / 8 articles
Every article tagged so-101, newest first.
After part 6: direct motor drive, learning between drawings, feedback during a stroke, and a twin tested across days. The repeat floor is not a claim of one-millimeter control.
so-101machine-learningcontrol
I get $10,000 worth of measurements from a $40 drawing tablet. Now I want the height of the pen too.
so-101measurementsensors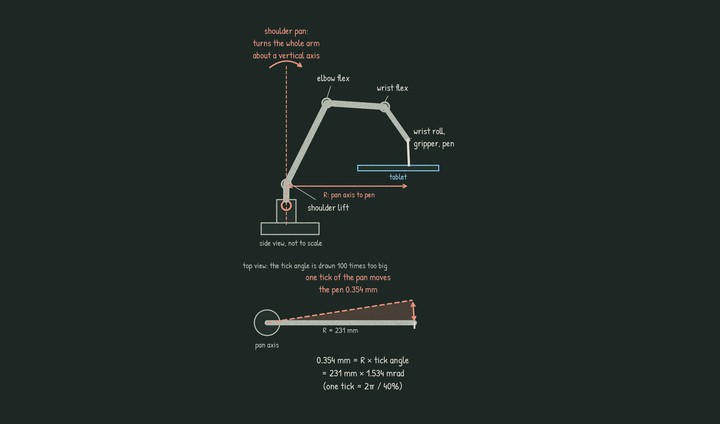
My SO-101 arm cannot see its own pen tip. A tablet can. Here is what the tablet showed: how much error a learned correction removes, which causes are left, and why the base joint matters most.
so-101calibrationmeasurement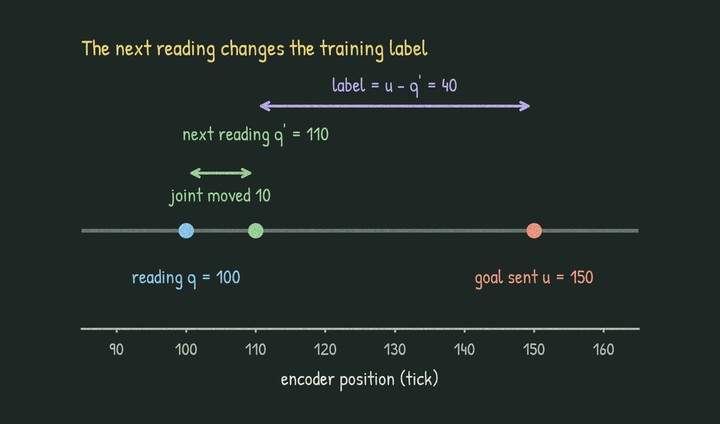
Where a neural network fits in a robot controller. A network that learns only what the physics model gets wrong does the same job as a Kalman disturbance estimate, with more freedom, and this is where recent research is going.
so-101controlmachine-learning
I want to see my SO-101 trajectory errors as ink on paper. For that, the pen must not add an error of its own. I made five holder designs. The one I release is a printed sleeve that slides onto the stock gripper: 4 printed parts, nothing to buy, any pen from 8 to 13 mm.
so-101hardware3d-printing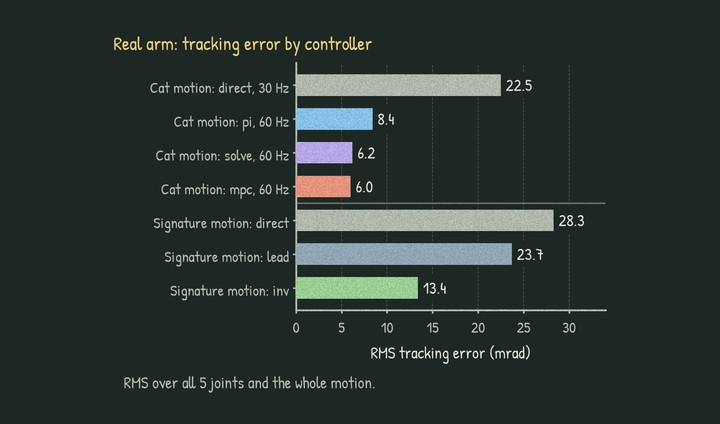
One general formula for the goal sent to a servo. Every controller I built, from a plain look-ahead to MPC, is that formula with some terms set to zero.
so-101control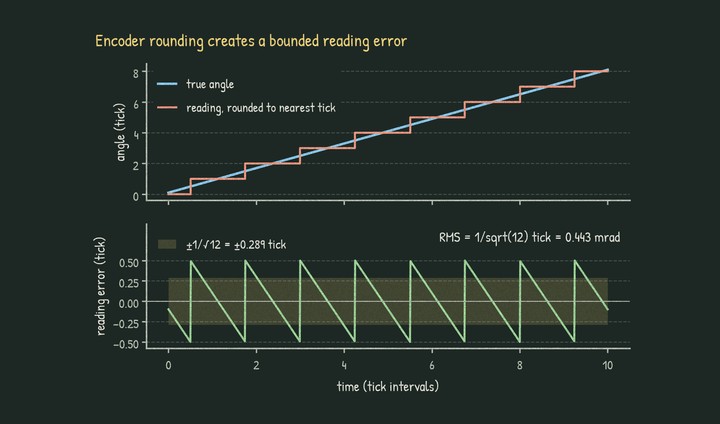
The sensor side of the joint equation: why differences of encoder ticks explode the noise, and how an observer or a Kalman filter can estimate an angle finer than one tick.
so-101controlsensors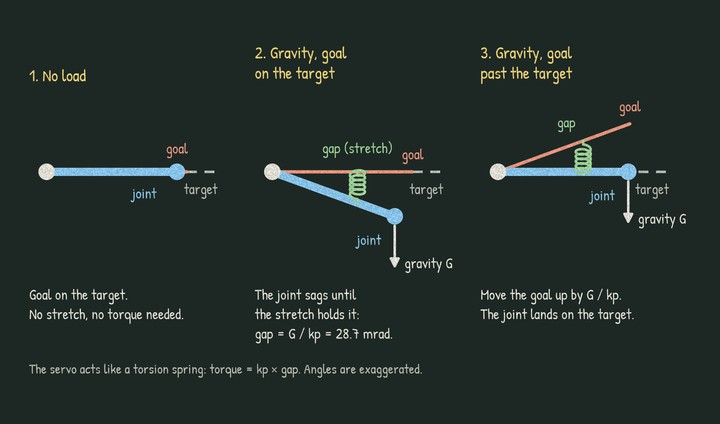
Start from torque = inertia × acceleration, then add each term a cheap servo arm really has: gravity, friction, a payload, dead time, a dead band. Each term is one way the arm misses its target.
so-101controlhardware